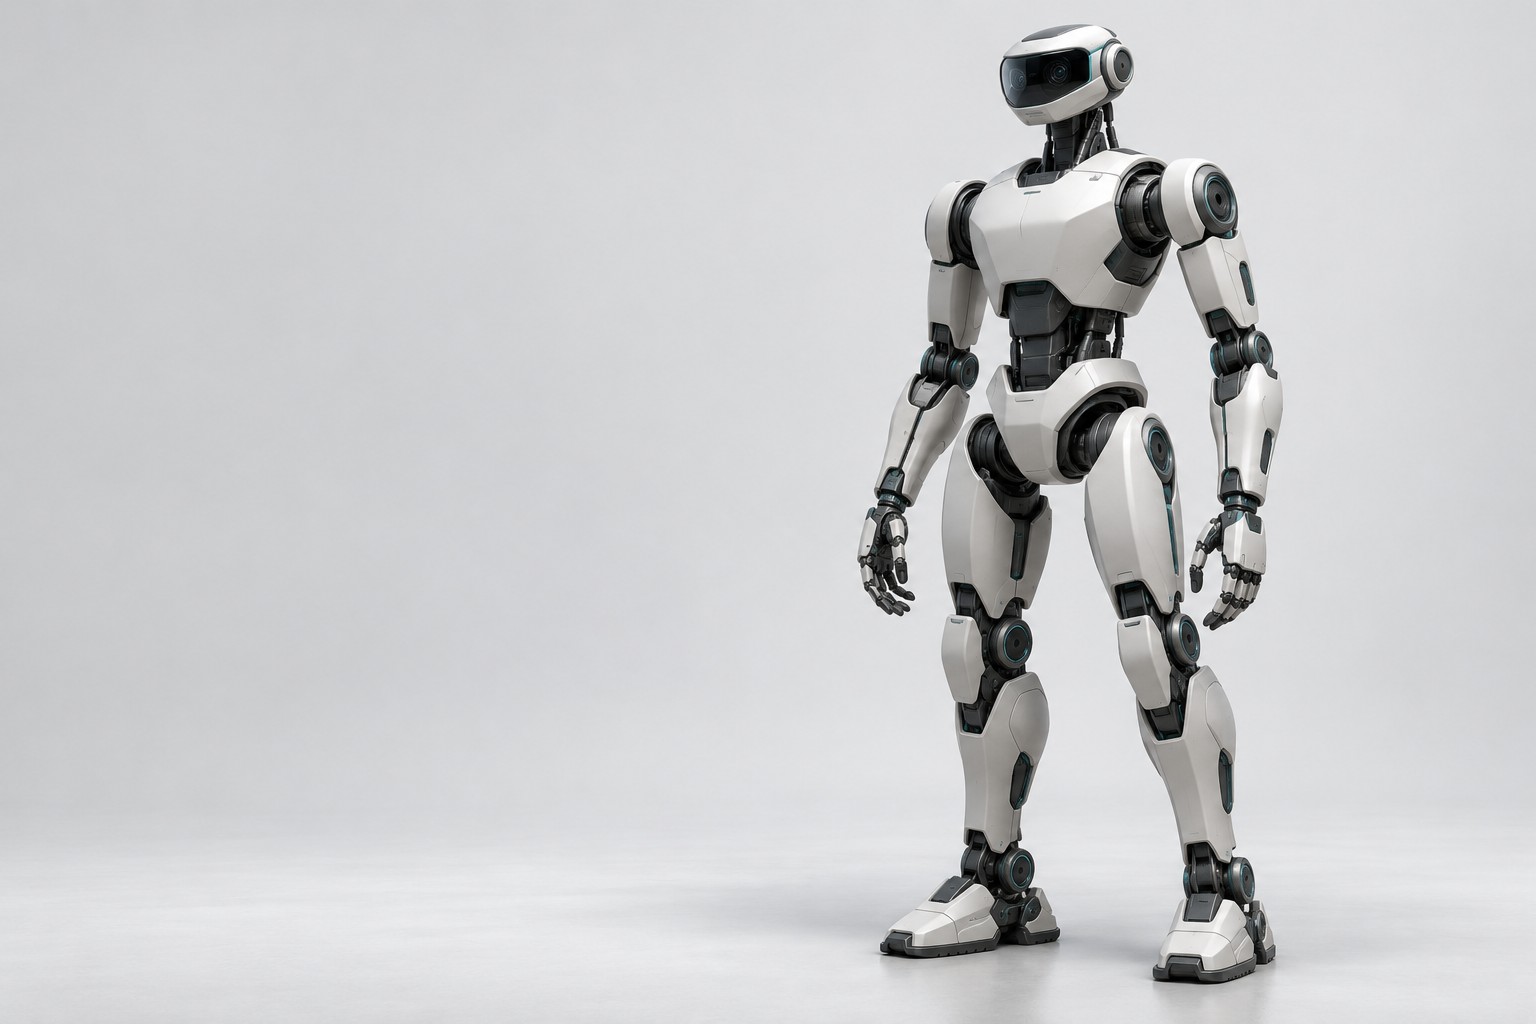
UNDER DEVELOPMENTPaarth R1
Humanoid robot development in India.
Exploring intelligent humanoid robots through balance, movement, and interaction research. Paarth R1 is HRL’s developing platform for humanoid robotics solutions.
2028Target sales readiness
Subject to development & validation
AI-generated design concept · Not an existing Paarth prototype
165–175 cmTarget height
36 DoFProposed baseline
2–5 kg / armTarget payload, posture dependent
60–120 minTarget endurance, duty-cycle dependent
DESIGNED FOR DISCOVERY
Think. Move. Learn.
One modular humanoid. A shared foundation for supervised research.
◎Perception
RGB-D and stereo vision, IMU sensing, and state estimation.
UNDERSTAND THE ENVIRONMENT↗Locomotion
Dynamic balance, bipedal gait planning, and whole-body control.
EXPLORE HUMAN-LIKE MOTION⌘Manipulation
Articulated arms and simplified grippers for supervised object-handling research.
TURN INTENT INTO ACTION
MODULAR BY DESIGN
From intelligence
to movement.
Research interfaces connect to motion planning and real-time controls. Independent safety layers retain authority over physical execution.
ROS 2PythonC++Simulation APIs
- 01
Paarth Intelligence
Perception · Task reasoning · Human interface
- 02
Paarth Skills
Walking · Reaching · Grasping
- 03
Paarth Motion
State estimation · Planning · Whole-body control
- 04
Paarth Core
Real-time control · Safety · Telemetry
THE PROPOSED PLATFORM
Engineering targets.
- Height
- 165–175 cm
- Mass
- 55–75 kg
- Joint configuration
- 30–40 DoF target range; proposed 36-DoF baseline
- Locomotion
- Two-legged dynamic walking
- Initial walking speed
- 0.5–1.0 m/s target
- Arm payload
- 2–5 kg per arm, subject to posture
- Battery endurance
- 60–120 minutes, duty-cycle dependent
- Perception
- RGB-D, stereo vision & IMU
- Computing
- GPU edge computer & real-time controllers
- Joint control frequency
- 500–1,000 Hz target
- Software & research interfaces
- Linux, ROS 2, Python, C++ & simulation APIs
- Planned safety systems
- Emergency stop, joint limits & monitored operation
All specifications are preliminary engineering targets. Performance, safety, and final configuration require prototype testing and validation.
THE ROAD AHEAD
Research first. Readiness next.
- 01 / DEVELOPMENT
Design & simulation
Architecture, actuator validation, digital twin, and safety concept.
- 02 / VALIDATION
Prototype & pilots
Supported locomotion, manipulation, research interfaces, and supervised pilot evaluation.
- 03 / TARGET: 2028
Sales readiness
Targeted after engineering validation, pilot acceptance, and production-readiness review.
Paarth R1 is under development and is not currently available for sale. The 2028 target may change with engineering progress and validation results.
BUILT FOR RESEARCHERS
Your next research question.
A new physical platform.
Universities · Robotics laboratories · Industrial R&D